理解人 Understand people
融合语言指令、场景观测、任务进度和历史记忆,理解复杂任务意图、执行约束和人类纠偏。 Fuses language, scene observation, task progress, and memory to understand intent, constraints, and human correction.
Oasis Brain 基于 World Action Model,嵌入机器人、智能设备和边缘系统,让机器理解人、会操作、能实时闭环,并在真实反馈中持续进化。 Oasis Brain explores the World Action Model inside robots, devices, and edge systems, enabling machines to understand people, operate physically, close the loop in real time, and improve through feedback.
面向真实场景的机器人,需要同时理解人类意图、生成可执行动作,并在部署反馈中持续学习。Oasis Brain 将这三类能力统一到同一个具身智能引擎中。 Robots in real environments need to understand human intent, generate executable actions, and keep learning from deployment feedback. Oasis Brain unifies these capabilities in one embodied intelligence engine.
融合语言指令、场景观测、任务进度和历史记忆,理解复杂任务意图、执行约束和人类纠偏。 Fuses language, scene observation, task progress, and memory to understand intent, constraints, and human correction.
基于物理环境、物体关系和硬件约束,规划长程任务,生成可执行、可适配、可评估的动作。 Plans long-horizon tasks and generates executable, adaptable, and evaluable actions from physical context and hardware constraints.
连接感知、推理和控制链路,将失败样本、执行结果和偏好反馈转化为持续学习的数据。 Connects perception, inference, and control while turning failures, execution results, and preference feedback into learning data.
Oasis Brain 不只输出下一步动作。它把当前状态、任务目标、人类输入和先验约束编码进同一个交互式模型,在生成动作的同时预测状态演化,形成“感知-决策-预测”的闭环。 Oasis Brain does not only output the next action. It encodes state, goals, human input, and prior constraints into an interactive model, generating actions while predicting state evolution.
Oasis Brain 承接 Trace、Data、World 生产出的真实数据、训练资产和仿真经验,再把真实部署反馈回流,驱动下一轮数据采集、训练和验证。 Oasis Brain consumes real data, training assets, and simulated experience from Trace, Data, and World, then returns deployment feedback to drive the next cycle.
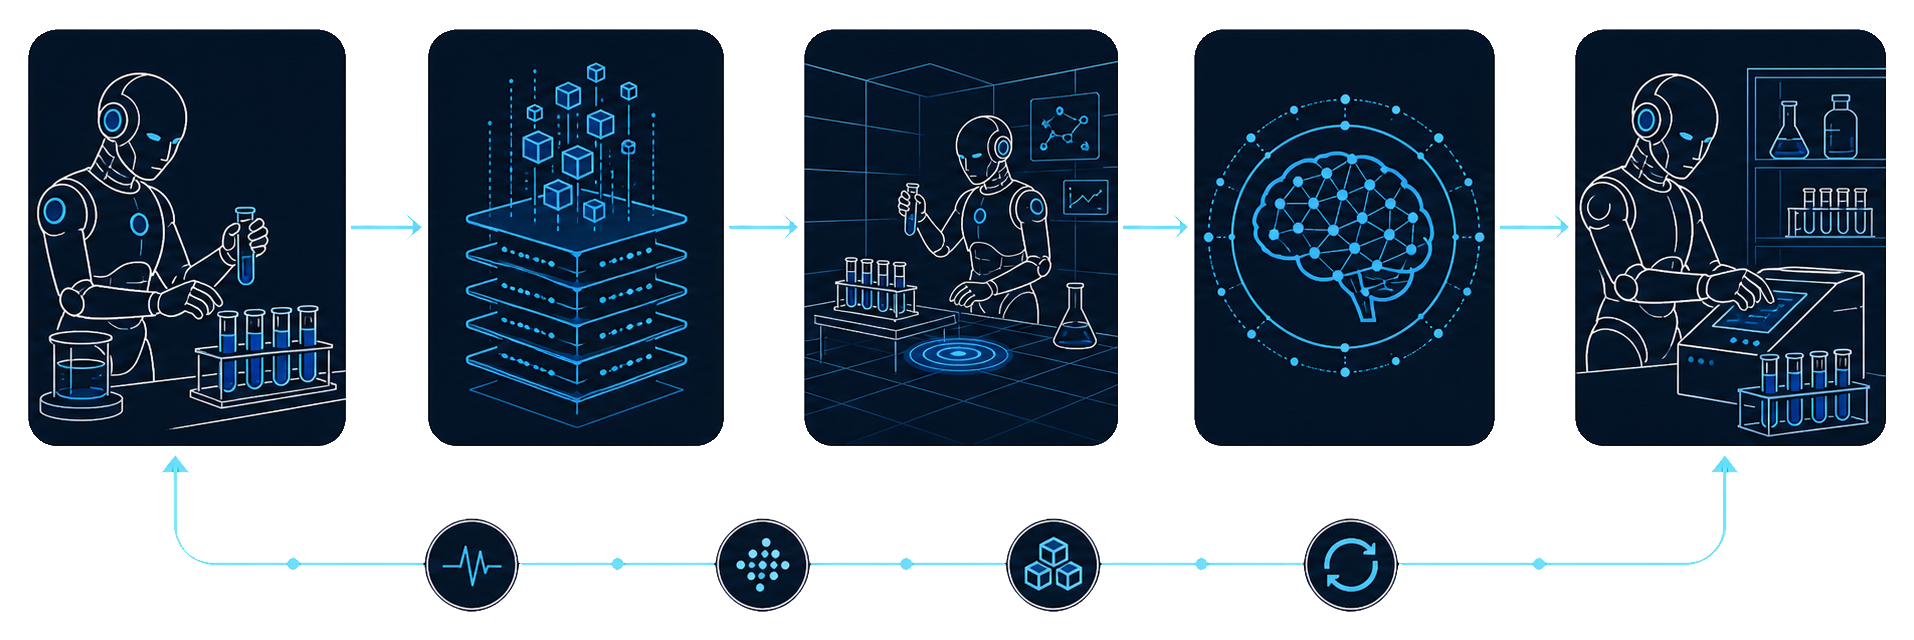
Oasis Brain 面向需要物理操作、空间理解和人机协作的真实系统,可嵌入科研机器人、智能设备、自动化作业系统,并逐步扩展到更多服务型本体。 Oasis Brain serves real systems that require physical operation, spatial understanding, and human-machine collaboration, from scientific robots and intelligent devices to automation systems and future service embodiments.
自主移动、长程任务规划、搬运上下料、仪器操作、状态确认。 Autonomous movement, long-horizon planning, sample transfer, instrument operation, state confirmation.
把设备操作、界面交互和边缘感知纳入统一任务上下文。 Unifies device operation, interface interaction, and edge perception in one task context.
在安全约束、任务约束和硬件约束下生成可执行策略。 Generates executable policies under safety, task, and hardware constraints.
从人机协作世界动作模型出发,扩展到家庭、教育和服务场景。 Extends from human-robot world-action models into home, education, and service contexts.